Quadruped Robot
// Project Information
- CategorySoftware-Hardware
-
Client
 enLS
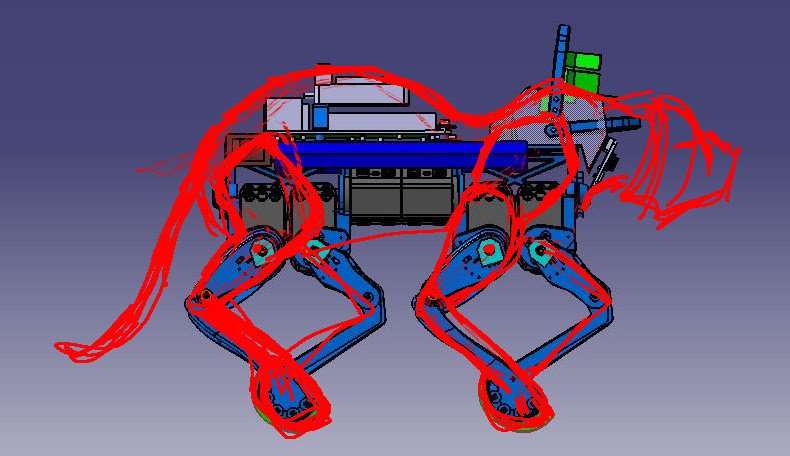
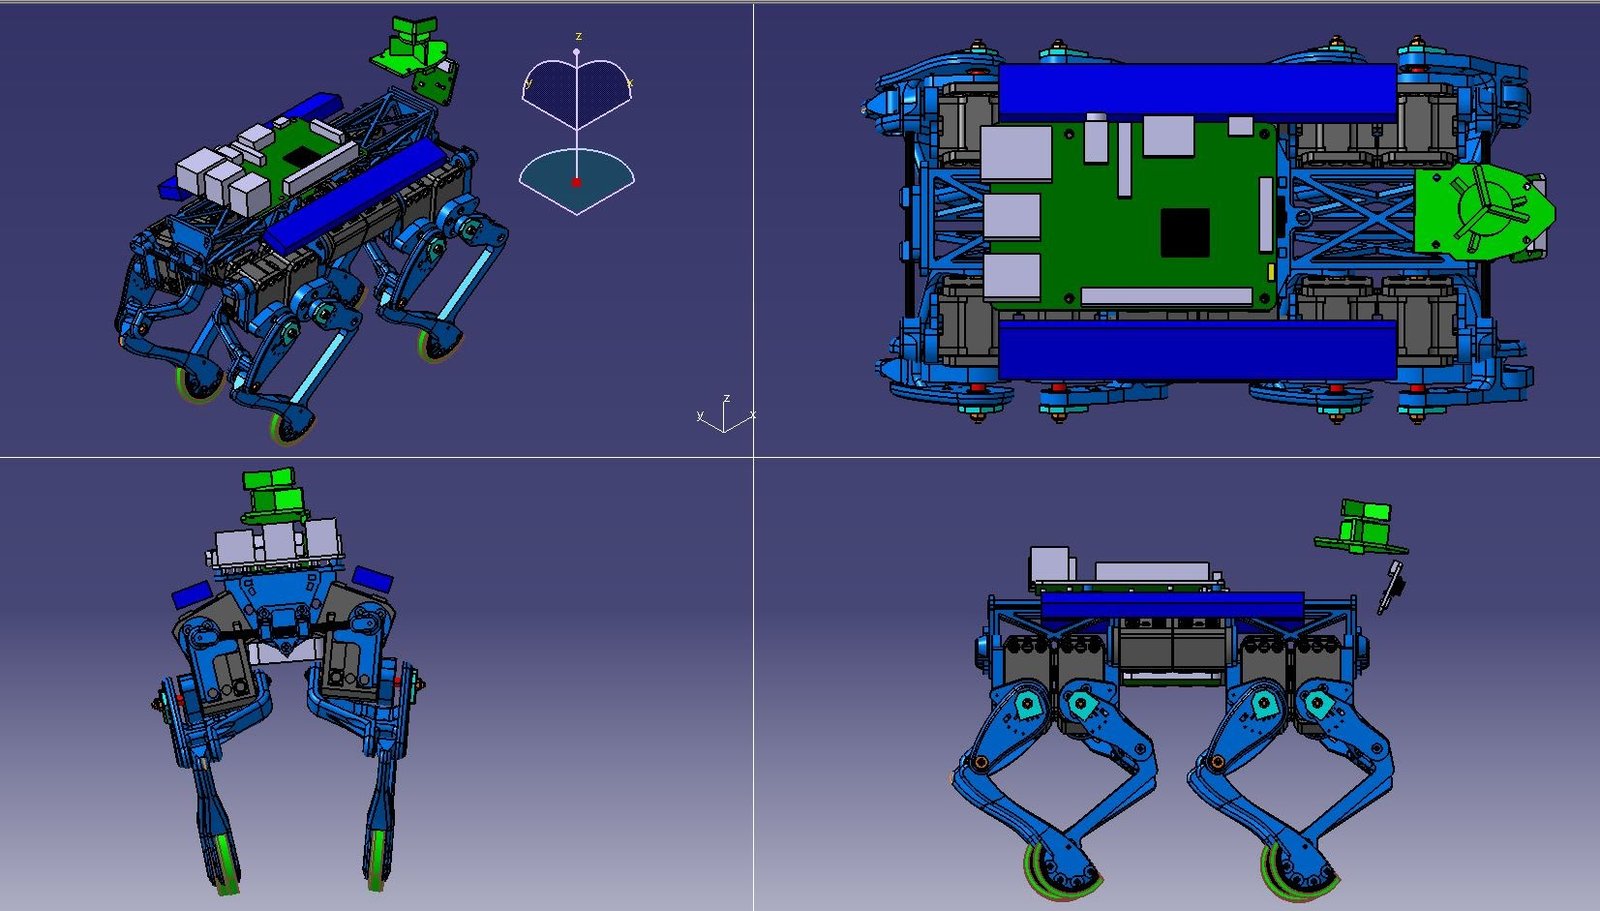
- Short DescriptionDesigned and developed a four-legged robotic cat, including custom PCB design, electronic hardware assembly, and programming. Created the robot's 3D model using CAD software and manufactured its components with a 3D printer. Integrated the hardware and software to control leg movements and support coordinated robotic motion.
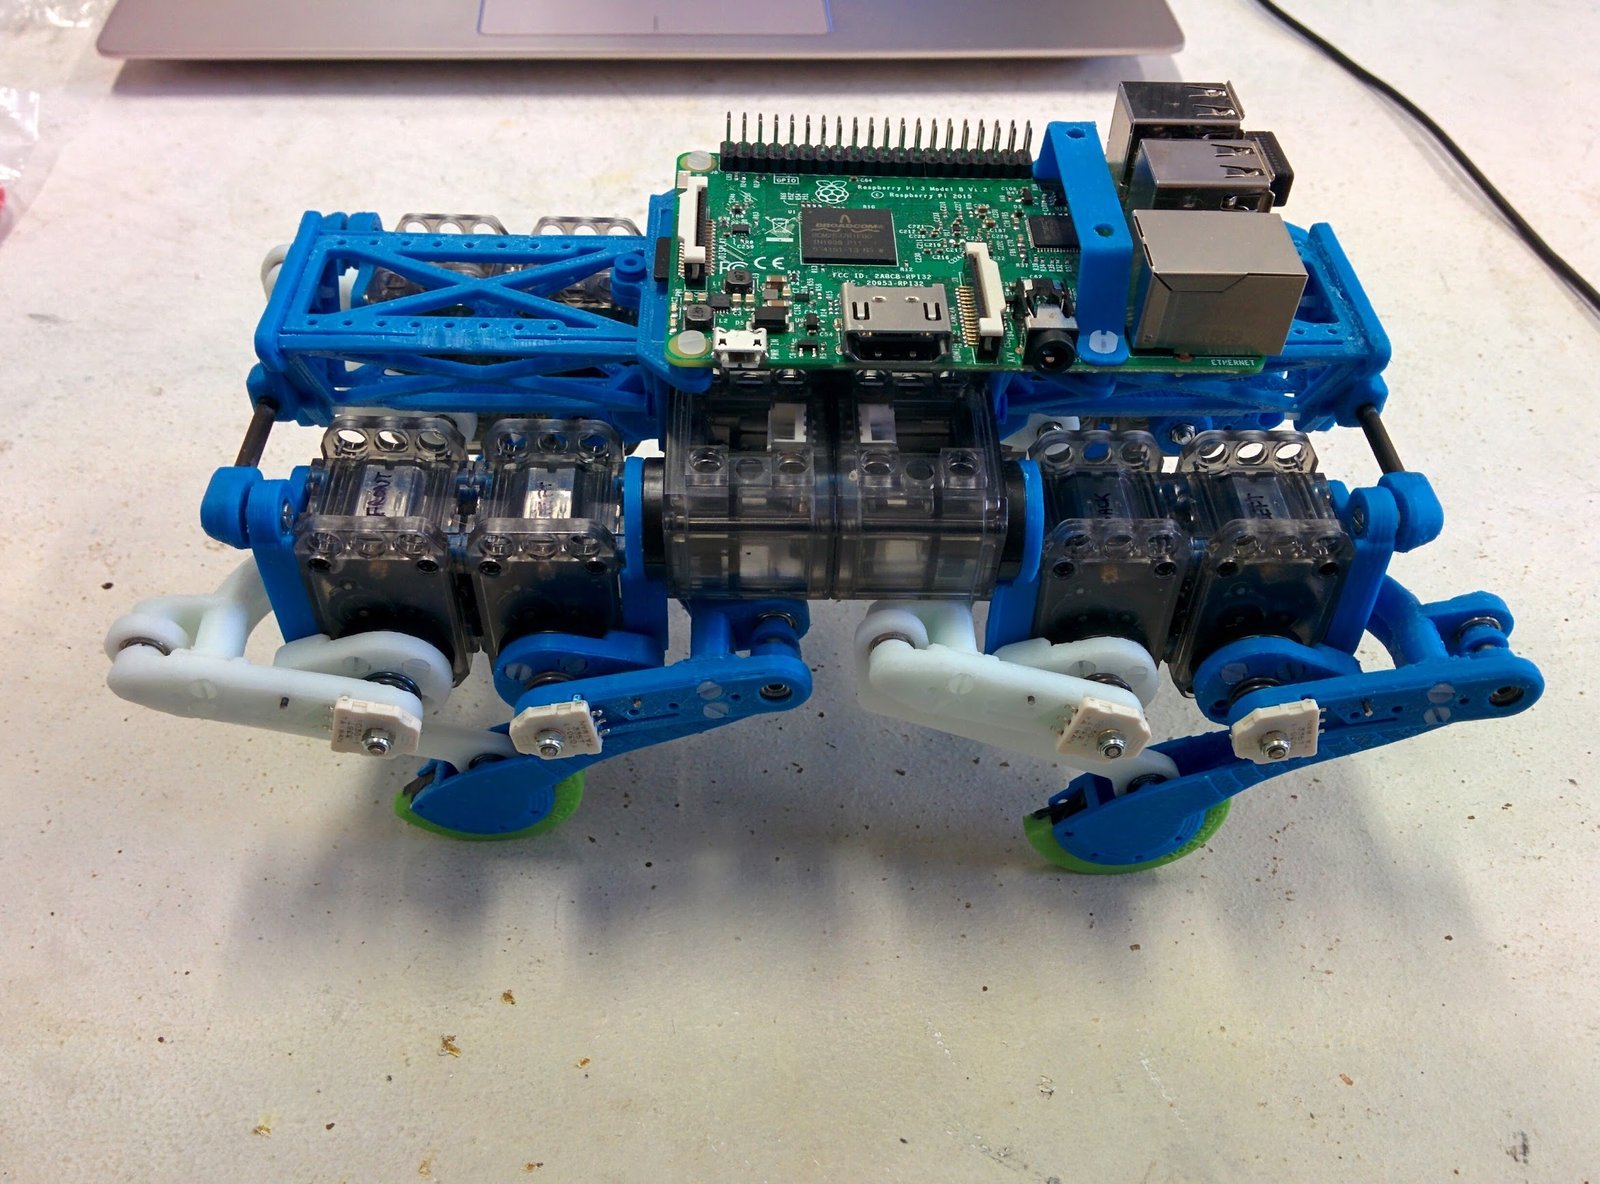
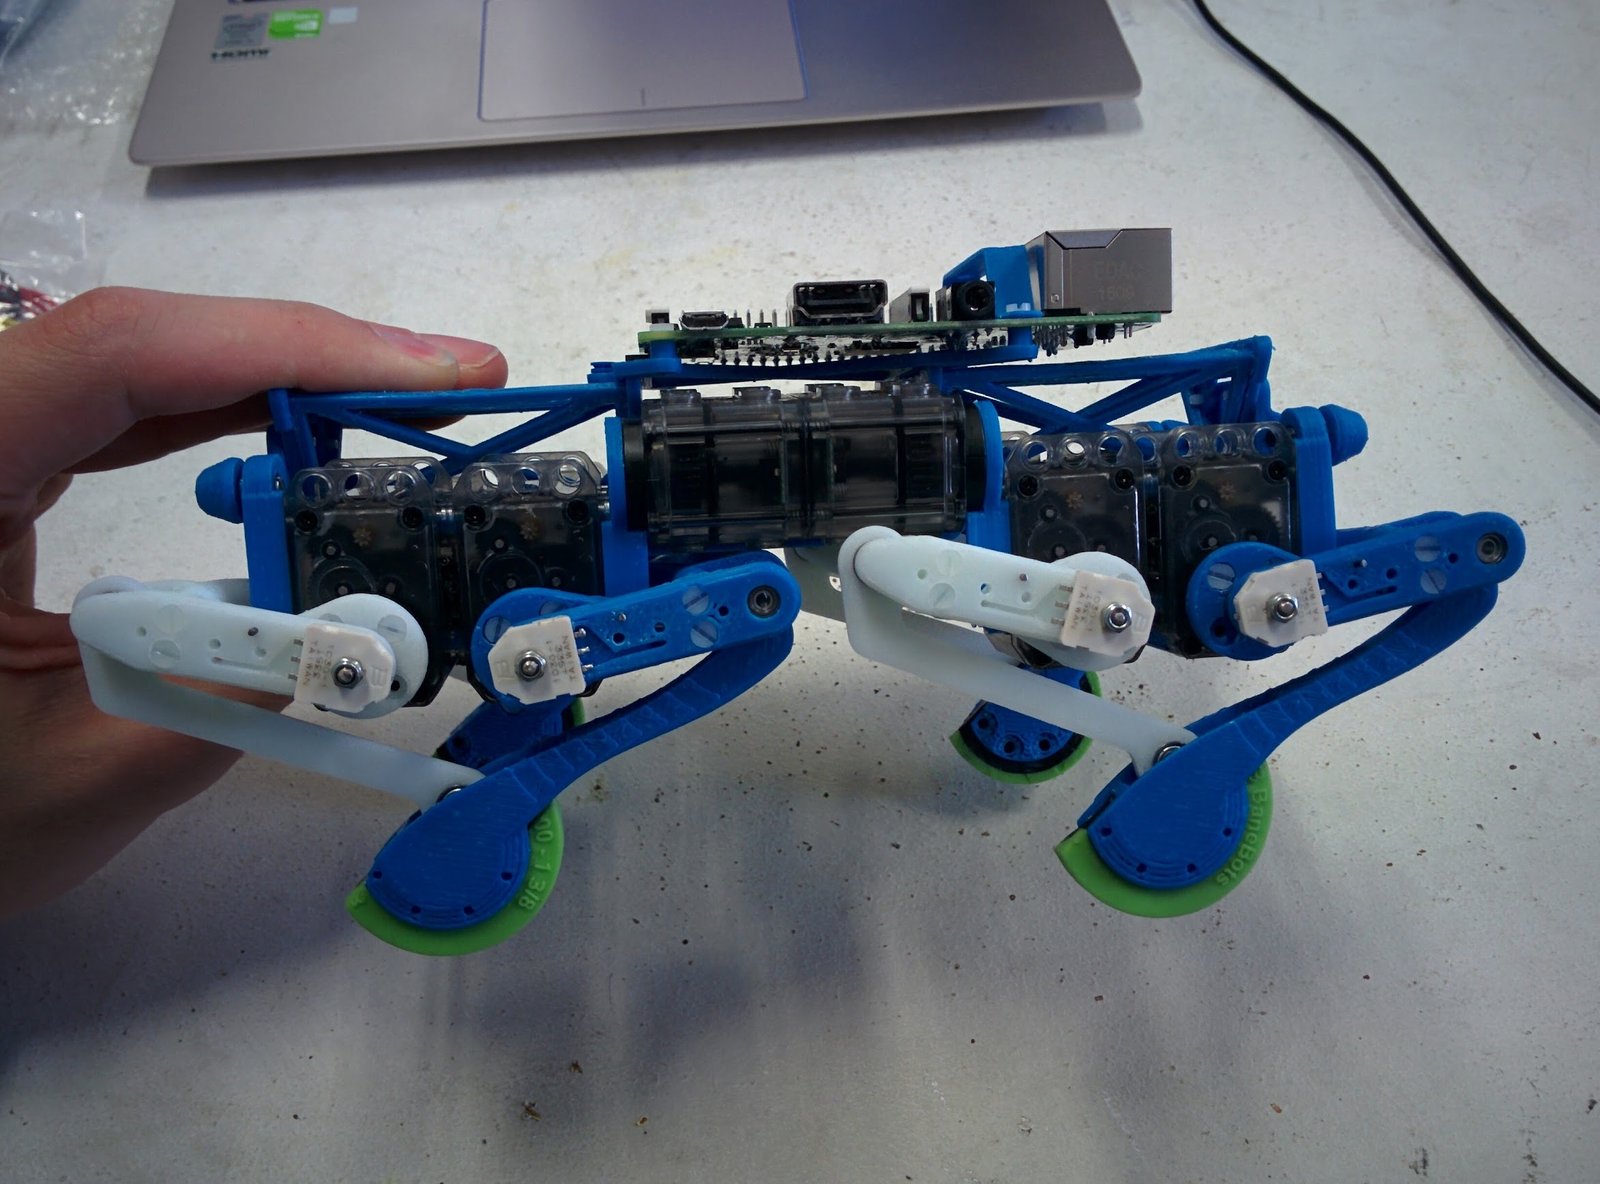
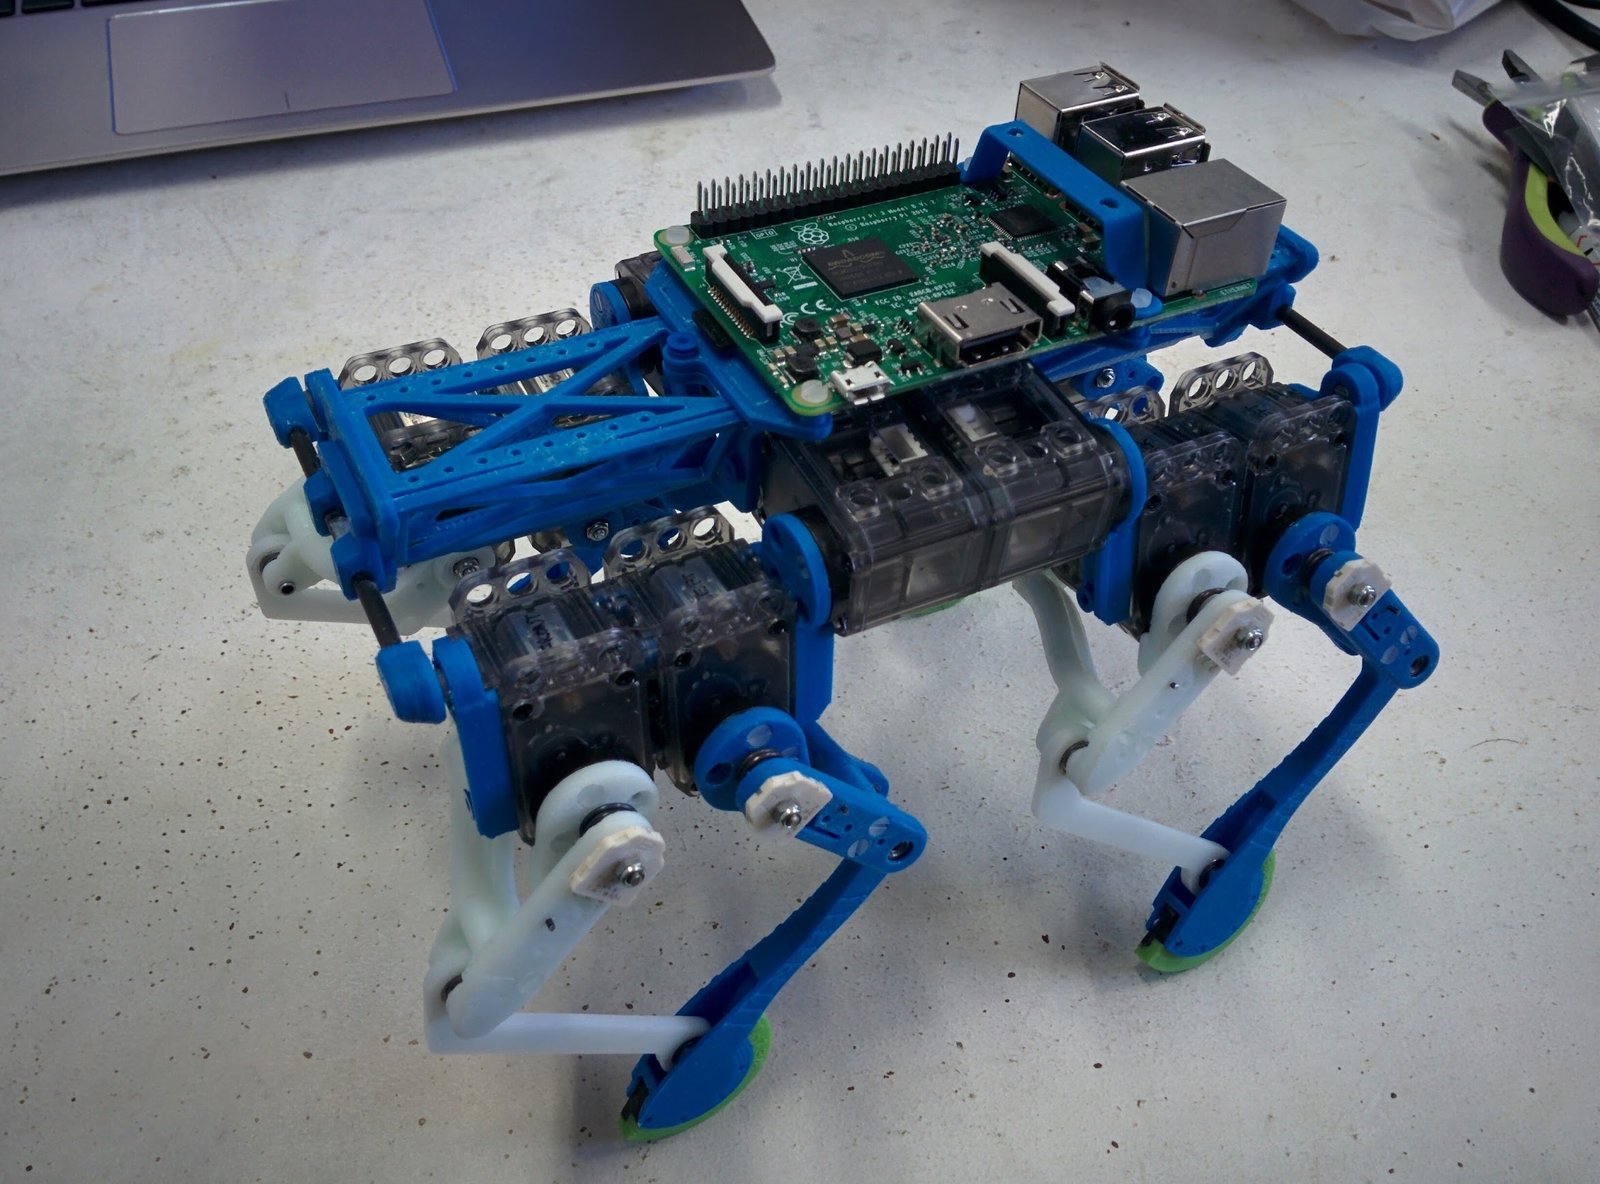
The Quadruped Robot is a four-legged robotic system inspired by the movement and structure of a cat. I designed and developed the robot from scratch, combining electronics, PCB design, embedded programming, mechanical engineering, and 3D printing to build a complete robotic prototype.
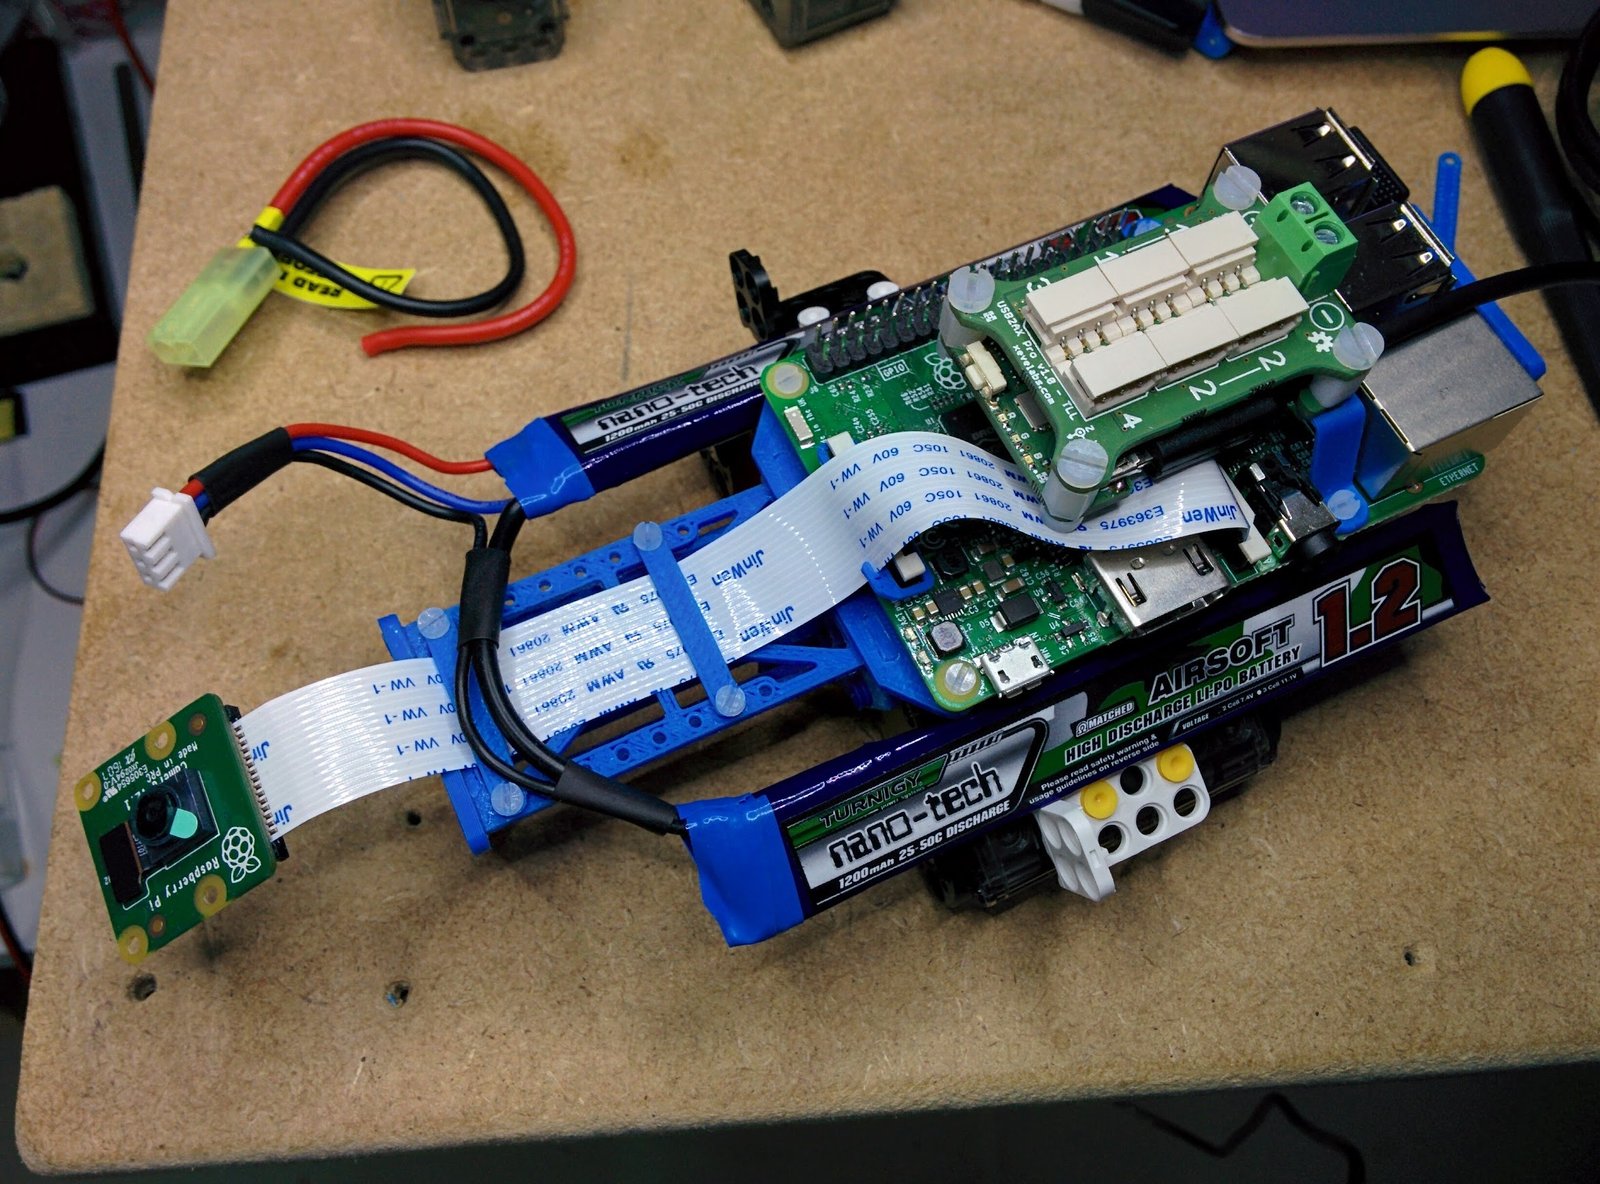
I designed the robot's electronic hardware and custom Printed Circuit Board (PCB), integrated the main electronic components, and developed the software required to control the robot's operation. I worked on the control system to coordinate the movement of the four legs and manage communication between the electronic components and the robot's actuators.
For the mechanical design, I created the robot's body and leg structures using 3D modeling software. I then manufactured the designed parts using a 3D printer, allowing me to customize the dimensions, reduce unnecessary weight, and assemble the mechanical structure according to the project requirements.
I also worked on the integration of the mechanical, electronic, and software components, considering factors such as weight distribution, joint positioning, balance, and coordinated leg movement. The development process involved assembling the robot, testing its components, and adjusting the design and programming to improve movement and overall operation.
This project demonstrates my practical experience in robotics, PCB design, embedded systems, programming, CAD modeling, 3D printing, and hardware-software integration. It reflects my ability to independently design and build a robotic system, from the initial concept and electronic circuits to the physical structure and movement control.